
pose estimation is incredibly useful; it is used in VR, AR, controller tracking, autonomous driving, and even satellite docking. Recall that for a pinhole camera model, the camera matrix P∈R3×4 is a projective mapping from world (3D) to pixel (2D) coordinates defined up to a scale.
\n\nThe distinction between camera coordinate and world coordinate systems is a rotation and a translation.\nWhen we combine translation and rotation matrix they convert points from the world to the camera coordinate system. An intuitive way to understand this is to think about how aligning the axes of the world coordinate system to the ones of the camera coordinate system can be done with a rotation and a translation.
\n\n
@mobassir thanks now m bit better. Help me with few more\n1) camera matrix given is Translation matrix ?\n2) p,y,r values are euler angles ? do we need to build rotation matrix out of it using eulers theorem\n3) x,y,z given along with pyr given are camera coordinates or world coordinates.\n4) in your center baseline where are u using euler to rotation function other than visualization.
", "rawMarkdown": "mobassir thanks now m bit better. Help me with few more\n1) camera matrix given is Translation matrix ?\n2) p,y,r values are euler angles ? do we need to build rotation matrix out of it using eulers theorem\n3) x,y,z given along with pyr given are camera coordinates or world coordinates.\n4) in your center baseline where are u using euler to rotation function other than visualization.", "votes": null }, { "id": "695533", "postDate": "12/15/2019 09:42:36", "content": "for 4. check code of 3d visualization section (cell 10)\nfor 1,2 and 3 please read past discussion posts and go through this link : http://www.opengl-tutorial.org/beginners-tutorials/tutorial-3-matrices/#translation-matrices
", "rawMarkdown": "for 4. check code of 3d visualization section (cell 10)\nfor 1,2 and 3 please read past discussion posts and go through this link : http://www.opengl-tutorial.org/beginners-tutorials/tutorial-3-matrices/#translation-matrices", "votes": null }, { "id": "695651", "postDate": "12/15/2019 12:26:24", "content": "Thanku..\nCoordinates we are provided with in train are Real world coordinates ?
", "rawMarkdown": "Thanku..\nCoordinates we are provided with in train are Real world coordinates ?", "votes": null }, { "id": "695661", "postDate": "12/15/2019 12:40:01", "content": "Input is a PredictionString (e.g. from train dataframe)\n Output is two arrays:\n xs: x coordinates in the image (row)\n ys: y coordinates in the image (column)
", "rawMarkdown": "Input is a PredictionString (e.g. from train dataframe)\n Output is two arrays:\n xs: x coordinates in the image (row)\n ys: y coordinates in the image (column)", "votes": null } ], "comments": [ { "id": 695493, "author_name": "jaideepvalani", "author_url": "", "post_date": "12/15/2019 08:37:22", "content": "@mobassir thanks now m bit better. Help me with few more\n1) camera matrix given is Translation matrix ?\n2) p,y,r values are euler angles ? do we need to build rotation matrix out of it using eulers theorem\n3) x,y,z given along with pyr given are camera coordinates or world coordinates.\n4) in your center baseline where are u using euler to rotation function other than visualization.
", "votes": null, "replies": [ { "id": 695533, "author_name": "mobassir", "author_url": "", "post_date": "12/15/2019 09:42:36", "content": "for 4. check code of 3d visualization section (cell 10)\nfor 1,2 and 3 please read past discussion posts and go through this link : http://www.opengl-tutorial.org/beginners-tutorials/tutorial-3-matrices/#translation-matrices
", "votes": null, "replies": [] }, { "id": 695651, "author_name": "jaideepvalani", "author_url": "", "post_date": "12/15/2019 12:26:24", "content": "Thanku..\nCoordinates we are provided with in train are Real world coordinates ?
", "votes": null, "replies": [] }, { "id": 695661, "author_name": "mobassir", "author_url": "", "post_date": "12/15/2019 12:40:01", "content": "Input is a PredictionString (e.g. from train dataframe)\n Output is two arrays:\n xs: x coordinates in the image (row)\n ys: y coordinates in the image (column)
", "votes": null, "replies": [] } ] } ], "raw_markdown_by_id": { "684279": "pose estimation is incredibly useful; it is used in VR, AR, controller tracking, autonomous driving, and even satellite docking. Recall that for a pinhole camera model, the camera matrix P∈R3×4 is a projective mapping from world (3D) to pixel (2D) coordinates defined up to a scale.\n\n# Reason for Rotation and Translation : \n\nThe distinction between camera coordinate and world coordinate systems is a rotation and a translation.\nWhen we combine translation and rotation matrix they convert points from the world to the camera coordinate system. An intuitive way to understand this is to think about how aligning the axes of the world coordinate system to the ones of the camera coordinate system can be done with a rotation and a translation.\n\n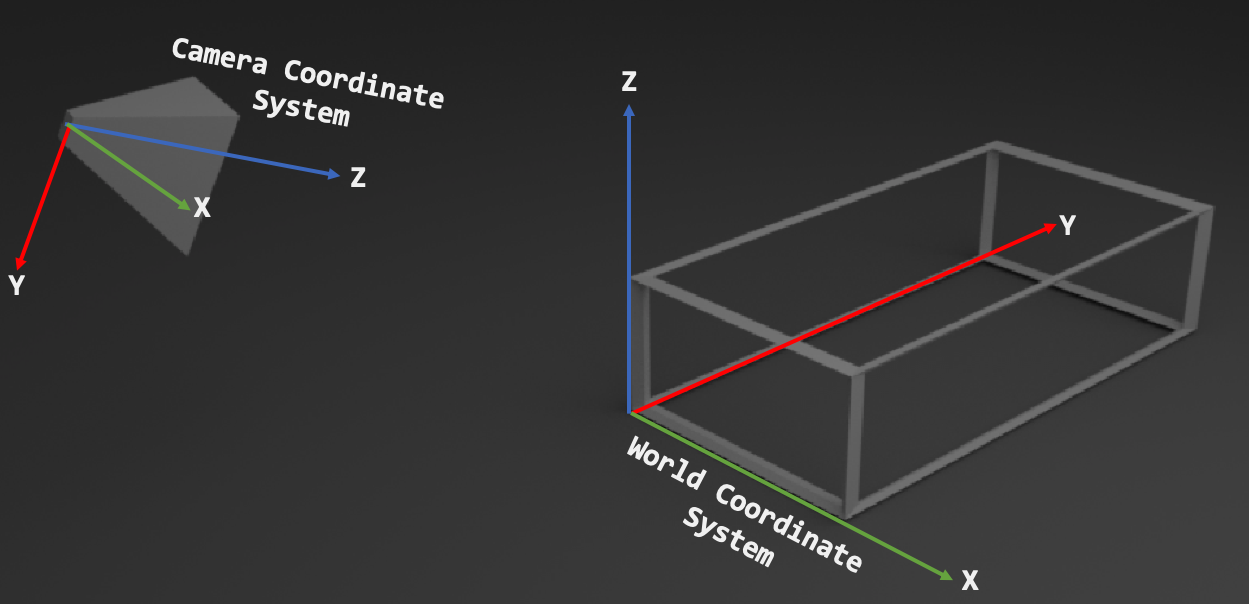", "695493": "mobassir thanks now m bit better. Help me with few more\n1) camera matrix given is Translation matrix ?\n2) p,y,r values are euler angles ? do we need to build rotation matrix out of it using eulers theorem\n3) x,y,z given along with pyr given are camera coordinates or world coordinates.\n4) in your center baseline where are u using euler to rotation function other than visualization.", "695533": "for 4. check code of 3d visualization section (cell 10)\nfor 1,2 and 3 please read past discussion posts and go through this link : http://www.opengl-tutorial.org/beginners-tutorials/tutorial-3-matrices/#translation-matrices", "695651": "Thanku..\nCoordinates we are provided with in train are Real world coordinates ?", "695661": "Input is a PredictionString (e.g. from train dataframe)\n Output is two arrays:\n xs: x coordinates in the image (row)\n ys: y coordinates in the image (column)" }, "source": "meta" }